Omron / Sentech Sentech STC-OSB250CL / STC-OSC250CL (25MP Camera Link)
STC-OSB250CL
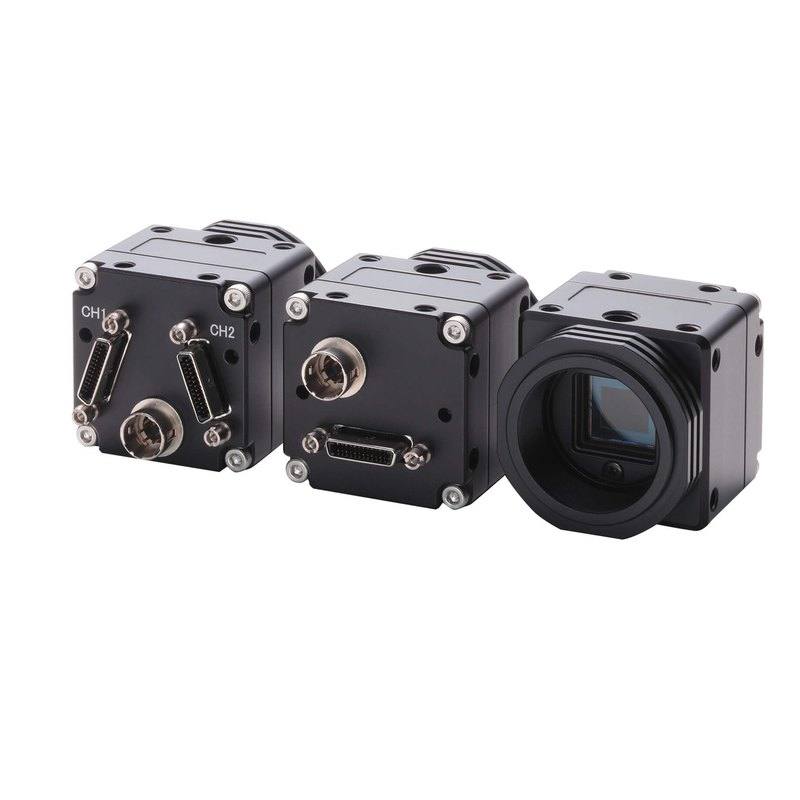
The STC-OSB250CL (mono) and STC-OSC250CL (color) are high-resolution area-scan cameras in Omron Sentech's STC Camera Link CMOS lineup. They use the 26.2 MP-class ON Semiconductor Python25K APS-H CMOS sensor at 5120 x 5120 active pixels with 4.5 µm square pixels and a global electronic shutter, reading out at approximately 31.8 fps at full resolution over a Camera Link interface. The camera uses an M42 lens mount to cover the large APS-H optical format and targets demanding high-resolution machine-vision tasks such as flat-panel, PCB/electronics, and wide-field defect inspection.
The Omron Sentech STC-OSB250CL (mono) and STC-OSC250CL (color) are 25 MP area-scan cameras built on ON Semiconductor's Python25K APS-H global-shutter CMOS sensor, delivering a 5120 x 5120 square pixel array from a 26.2 MP-class sensor. The combination of a 25 MP square format and a true global electronic shutter is the defining trait here: every pixel is exposed simultaneously, so you can freeze parts moving on a conveyor or indexing stage without the geometric skew that a rolling shutter introduces. At full resolution the camera reads out at roughly 31.8 fps, which is fast for a sensor of this size and means it can support reasonable line throughput even when each frame carries over 26 million pixels of detail.
The 4.5 µm square pixels on an APS-H optical format give the camera a large imaging area, which is why it carries an M42 lens mount rather than a C-mount. M42 (and larger image-circle optics) are needed to cover the full APS-H sensor without vignetting or corner falloff, so lens selection is a central part of designing this camera in. The high pixel count translates directly into spatial resolution at the part: across a given field of view you resolve 5120 pixels in each axis, which is what lets the camera catch fine defects, small features, and tight dimensional tolerances over a wide scene without tiling multiple lower-resolution cameras.
The interface is Camera Link, a deterministic, low-latency parallel link that is well suited to streaming the large frames this 25 MP sensor produces with stable timing and hardware triggering. Camera Link requires a matching frame grabber in the host PC and a cabling run kept within the interface's length limits, but in return it gives you the bandwidth and timing precision that high-resolution inspection lines depend on. The monochrome STC-OSB250CL maximizes sensitivity and resolving power for grayscale defect, metrology, and OCR-style tasks, while the color STC-OSC250CL trades some of that for color discrimination where part appearance or print color matters.
Best for
Wide-field defect and surface inspection on flat panels, glass, and webbed materials where 5120 x 5120 resolution lets one camera cover an area that would otherwise need several lower-resolution sensors
PCB and electronics inspection requiring fine feature resolution and accurate dimensional measurement across a large field of view
High-resolution dimensional measurement and metrology where the global shutter keeps moving parts geometrically true for sub-pixel gauging
Semiconductor and flat-panel inspection that demands both high pixel count and freeze-frame capture of indexed or moving substrates
Packaging and print inspection where the color STC-OSC250CL variant adds color discrimination for label, print, and appearance checks
Selection notes
Plan for a Camera Link frame grabber and qualified Camera Link cabling in the host PC; this is not a plug-and-network camera like GigE or USB3, so the grabber, cable length, and configuration must be designed into the system up front
Budget for M42 optics with an image circle large enough to cover the APS-H format; standard C-mount lenses will vignette, and at 4.5 µm pixels the lens must resolve enough detail to actually exploit the 25 MP sensor
Choose between the monochrome STC-OSB250CL and color STC-OSC250CL early: mono gives maximum sensitivity and resolving power for grayscale inspection and metrology, while color is only worth the trade-off when part or print color is part of the decision
At full 5120 x 5120 resolution the camera runs at about 31.8 fps; if your line speed needs higher rates, confirm whether region-of-interest or binning modes meet your timing rather than assuming full-frame throughput
Pair the global shutter with appropriately bright, well-controlled lighting and hardware triggering; the large sensor area and short freeze-frame exposures on fast lines demand enough illumination to keep images clean, and Camera Link's deterministic triggering supports tight strobe synchronization
Specifications: General
Brand
Omron / Sentech
Camera type
Area scan
Specifications: Sensor
Resolution
25 MP (26.2 MP sensor)
Horizontal resolution
5120 x 5120 px
Mono / color
Mono (STC-OSB250CL) / Color (STC-OSC250CL)
Sensor manufacturer
ON Semiconductor
Sensor model
ON Semi Python25K (PYTHON 25K)
Shutter
Global shutter
Sensor size
APS-H optical format
Pixel size
4.5 µm x 4.5 µm
Specifications: Performance
FPS
31.8 fps at full resolution
Specifications: Interface
Interface
Camera Link
Specifications: Optics
Mount
M42 mount
Applications this camera is commonly selected for. Open one to see the full recommended hardware and approach.
Matched automatically by: lens mount fits the camera mount · lens image circle covers the camera sensor — this camera: M42 mount · APS-H optical format sensor.
These steps take an Omron Sentech (STC) camera from the box to a stable first image and on to your own application. They apply across the GigE Vision, USB3 Vision and CoaXPress STC families; the interface only changes how you cable and power the camera.
Download and install the Sentech SDK on the host PC. The package provides StViewer, the viewing and configuration software you use to bring the camera up, and StApi, the programming SDK you integrate later. Because the cameras are GenICam/GenTL-compliant, StApi also registers a GenTL producer, so any GenICam-compliant third-party vision software can discover and drive the camera as an alternative front end.
2. Cable, power and connect the camera
Connect according to the interface. GigE Vision: link to a Gigabit NIC (use PoE or the separate power input) and put the camera and host on the same subnet; for USB3 Vision use a USB 3.x port and a certified cable; for CoaXPress (STC) connect to a CoaXPress frame grabber, which also supplies Power-over-Coax. Then open StViewer and let it enumerate the camera. If a GigE camera does not appear, check the IP configuration and firewall, and on USB3 confirm the host bandwidth and driver.
3. Configure exposure, gain and white balance
Open the device in StViewer and start a live stream. Set exposure and gain for a well-exposed, low-noise image: raise exposure first and only add gain when more light or a faster shutter is not an option, keeping exposure short enough to freeze motion on global-shutter models. On colour cameras, run white balance under your actual production lighting. Adjust the lens aperture and focus on a representative target before tuning anything else.
4. Set the trigger and grab a first image
Start in free-run (continuous) acquisition to confirm a clean, stable image. For inline inspection switch to hardware or software triggering: select the trigger source, set the active edge and any delay, and wire the strobe or illumination to the camera's I/O so lighting fires with each exposure. Acquire and save a frame in StViewer; this saved image is your reference for the SDK stage and for downstream inspection.
5. Move to the StApi SDK (or any GenICam software)
Once the image is stable, reproduce the same settings in code. Use StApi to open the device, apply the GenICam features you validated in StViewer (exposure, gain, trigger, pixel format) and grab frames into your application via the bundled C++, C, C#/.NET or Python interfaces; the included samples are the fastest starting point. Prefer a different stack? The same GenICam/GenTL camera works with third-party vision libraries. With a reliable feed, you can route it into a deep-learning inspection such as Rosepetal for AI-based defect detection.
Frequently asked questions
It uses the ON Semiconductor Python25K APS-H global-shutter CMOS sensor at 5120 x 5120 active pixels (25 MP, from a 26.2 MP-class sensor) with 4.5 µm square pixels.
It has a global electronic shutter, so the entire frame is exposed at once. That lets it image moving or indexed parts without the geometric distortion a rolling shutter would cause.
It uses a Camera Link interface, which requires a matching Camera Link frame grabber in the host PC and cabling kept within the interface's length limits. In return it provides deterministic, low-latency streaming and hardware triggering for the large frames the 25 MP sensor produces.
It uses an M42 mount to cover the large APS-H optical format. Standard C-mount lenses are not appropriate because they would not cover the full sensor without vignetting.
It reads out at approximately 31.8 fps at the full 5120 x 5120 resolution.
Yes. The STC-OSB250CL is the monochrome version and the STC-OSC250CL is the color version, both based on the same Python25K sensor.