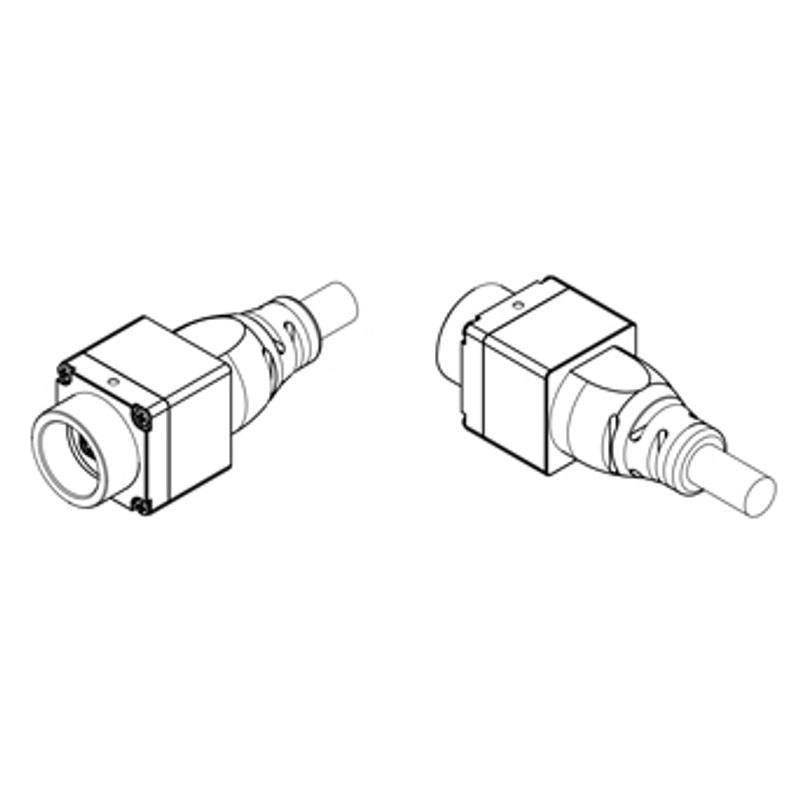
The STC-RBS43PCL-SM12 (monochrome) and STC-RCS43PCL-SM12 (color) are remote-head industrial area-scan cameras using a 1/2.9-inch Sony IMX287 CMOS global-shutter sensor at 0.4 MP (720 x 540, 6.9 µm pixels) and outputting over a Camera Link Base interface at up to 532.6 fps. The remote-head design splits the system into a tiny 18 (W) x 18 (H) x 23.42 (D) mm camera head connected by a 2.5 m cable to an 80 x 65 x 16 mm camera control unit (CCU), with an S-mount (M12 P=0.5) lens mount. The camera is powered via PoCL or external +12 VDC, draws 2.0 W or less, and offers exposure from 1 µs to 16.777 s with 0-18 dB analog gain. Pixel formats are Mono8/10/12 for the mono model and BayerRG8/10/12 for the color model.
The defining trait of the STC-RBS43PCL-SM12 (mono) and STC-RCS43PCL-SM12 (color) is its remote-head architecture: an 18 x 18 x 23.42 mm camera head tied by a 2.5 m cable to a separate 80 x 65 x 16 mm camera control unit (CCU). That split lets you mount only a cube-sized head deep inside a fixture, a robot wrist, or a cramped enclosure while the bulk of the electronics and the Camera Link Base connector live on the CCU. The head carries a 1/2.9-inch Sony Pregius IMX287 CMOS global-shutter sensor at 0.4 MP (720 H x 540 V, 6.9 um pixels). Global shutter is the key imaging fact here: every pixel is exposed simultaneously, so parts moving past the camera, indexing on a conveyor, or carried on a robot arm are captured without the skew or smear a rolling-shutter sensor would introduce.
Throughput is the other headline. Over the Camera Link Base interface the camera runs up to 532.6 fps at full 720 x 540 resolution, and exposure is adjustable from 1 us to 16.777 s with 0-18 dB analog gain. The very short minimum exposure paired with the high frame rate makes this a tool for catching fast, repetitive events: counting or gauging parts on a high-index line, freezing motion under strobed light, or grabbing many frames of a single part for averaging or multi-shot inspection. The trade-off is a relatively low pixel count (0.4 MP), so this sensor is built for speed and motion fidelity rather than fine spatial detail.
Practical integration is straightforward but specific. The lens mount is S-mount (M12, P=0.5), so you fit compact board-level M12 lenses sized to the 1/2.9-inch format rather than C-mount optics; choose focal length to set field of view and working distance around the small sensor. Power comes via PoCL (Power over Camera Link) or external +12 VDC, and the head draws 2.0 W or less, so a single Camera Link cable can both power and read out the camera when the frame grabber supports PoCL. Pixel formats are Mono8/10/12 on the RBS model and BayerRG8/10/12 on the RCS color model, giving headroom for higher bit-depth output when contrast or grading demands it. The system weighs about 300 g and is rated for 0 to +44 C operating temperature, which bounds where the head and CCU can live without added cooling.
Best for
High-speed inspection or part counting on fast-indexing conveyors where the global shutter freezes motion at up to 532.6 fps
Robot-guidance and end-of-arm vision where the tiny 18 mm head must mount in a wrist or gripper while the CCU sits remotely
Embedding into compact fixtures, enclosures, or tight machine spaces that cannot accommodate a full-body camera
Strobe-synchronized acquisition of moving parts, using the 1 us minimum exposure to capture motion-frozen frames
Multi-frame capture of a single part (averaging or sequential lighting) where the high frame rate shortens cycle time
Selection notes
At 0.4 MP (720 x 540) this is a speed-and-motion sensor, not a high-resolution one; if the task needs fine feature detail across a large field, the pixel count will be the limiting factor.
The interface is Camera Link Base, so you must budget for a compatible frame grabber; confirm it supports PoCL if you want to power the head over the same cable rather than supplying external +12 VDC.
Plan around the remote-head split: only the 18 x 18 x 23.42 mm head goes at the inspection point, with a 2.5 m cable to the 80 x 65 x 16 mm CCU, so route and secure that fixed-length cable in your mechanical design.
Optics are S-mount (M12, P=0.5) for the 1/2.9-inch format; select an M12 lens whose focal length sets the field of view and working distance you need, since C-mount lenses will not fit.
Choose between models at order time: STC-RBS43PCL-SM12 is monochrome (Mono8/10/12) for maximum sensitivity and contrast, while STC-RCS43PCL-SM12 is color (BayerRG8/10/12) where hue matters; verify the head operates within the 0 to +44 C rating at its mount location.
Specifications: General
Brand
Omron / Sentech
Camera type
Area scan
Specifications: Sensor
Resolution
0.4 MP
Horizontal resolution
720 px (720 H x 540 V)
Mono / color
Mono (RBS) / Color (RCS)
Sensor manufacturer
Sony Pregius (IMX287)
Sensor model
Sony IMX287 CMOS
Shutter
Global shutter
Sensor size
1/2.9 inch optical format
Pixel size
6.9 x 6.9 µm
Specifications: Performance
FPS
532.6 fps (max)
Specifications: Interface
Interface
Camera Link Base
Specifications: Optics
Mount
S-mount (M12 P=0.5)
Specifications: Electrical
Power
PoCL or external +12 VDC
Power consumption
2 W
Specifications: Environment
Operating temperature
0 to +44 °C
Specifications: Mechanical
Dimensions
18 (W) x 18 (H) x 23.42 (D) mm
Weight
300 g
Applications this camera is commonly selected for. Open one to see the full recommended hardware and approach.
We could not derive compatible lenses from the available data for this camera.
Matched automatically by: lens mount fits the camera mount · lens image circle covers the camera sensor — this camera: S-mount (M12 P=0.5) · 1/2.9 inch optical format sensor.
These steps take an Omron Sentech (STC) camera from the box to a stable first image and on to your own application. They apply across the GigE Vision, USB3 Vision and CoaXPress STC families; the interface only changes how you cable and power the camera.
Download and install the Sentech SDK on the host PC. The package provides StViewer, the viewing and configuration software you use to bring the camera up, and StApi, the programming SDK you integrate later. Because the cameras are GenICam/GenTL-compliant, StApi also registers a GenTL producer, so any GenICam-compliant third-party vision software can discover and drive the camera as an alternative front end.
2. Cable, power and connect the camera
Connect according to the interface. GigE Vision: link to a Gigabit NIC (use PoE or the separate power input) and put the camera and host on the same subnet; for USB3 Vision use a USB 3.x port and a certified cable; for CoaXPress (STC) connect to a CoaXPress frame grabber, which also supplies Power-over-Coax. Then open StViewer and let it enumerate the camera. If a GigE camera does not appear, check the IP configuration and firewall, and on USB3 confirm the host bandwidth and driver.
3. Configure exposure, gain and white balance
Open the device in StViewer and start a live stream. Set exposure and gain for a well-exposed, low-noise image: raise exposure first and only add gain when more light or a faster shutter is not an option, keeping exposure short enough to freeze motion on global-shutter models. On colour cameras, run white balance under your actual production lighting. Adjust the lens aperture and focus on a representative target before tuning anything else.
4. Set the trigger and grab a first image
Start in free-run (continuous) acquisition to confirm a clean, stable image. For inline inspection switch to hardware or software triggering: select the trigger source, set the active edge and any delay, and wire the strobe or illumination to the camera's I/O so lighting fires with each exposure. Acquire and save a frame in StViewer; this saved image is your reference for the SDK stage and for downstream inspection.
5. Move to the StApi SDK (or any GenICam software)
Once the image is stable, reproduce the same settings in code. Use StApi to open the device, apply the GenICam features you validated in StViewer (exposure, gain, trigger, pixel format) and grab frames into your application via the bundled C++, C, C#/.NET or Python interfaces; the included samples are the fastest starting point. Prefer a different stack? The same GenICam/GenTL camera works with third-party vision libraries. With a reliable feed, you can route it into a deep-learning inspection such as Rosepetal for AI-based defect detection.
Frequently asked questions
It uses a 0.4 MP Sony IMX287 sensor at 720 x 540 pixels and runs up to 532.6 fps over Camera Link Base, making it a high-speed, motion-oriented camera rather than a high-resolution one.
It has a global shutter, so all pixels expose at the same instant. That lets it capture moving parts, conveyor-indexed objects, or robot-carried items without the skew or smear a rolling shutter would cause.
The camera splits into a tiny 18 x 18 x 23.42 mm head and a separate 80 x 65 x 16 mm camera control unit (CCU), joined by a 2.5 m cable, so only the small head needs to fit at the inspection point.
It uses an S-mount (M12, P=0.5) lens mount sized for the 1/2.9-inch sensor, and it is powered by PoCL or external +12 VDC, drawing 2.0 W or less.
Yes. The STC-RBS43PCL-SM12 is monochrome with Mono8/10/12 output, and the STC-RCS43PCL-SM12 is color with BayerRG8/10/12 output.