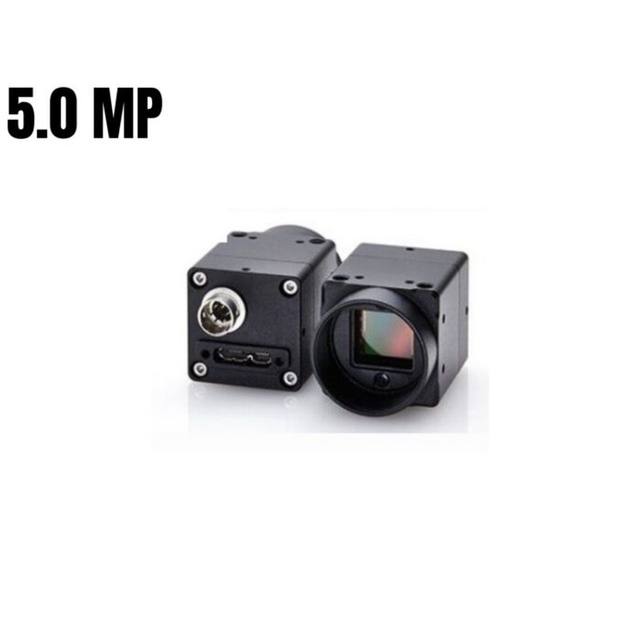
Monochrome line scan camera with a 2048-pixel AWAIBA DR-2K-7 CMOS line sensor at 7 um pixel pitch, delivering up to 80 kHz line rate (85 MHz x 2-tap) over a Camera Link Base interface with 8/10-bit output. F-mount and C-mount, +12 to +24 Vdc power.
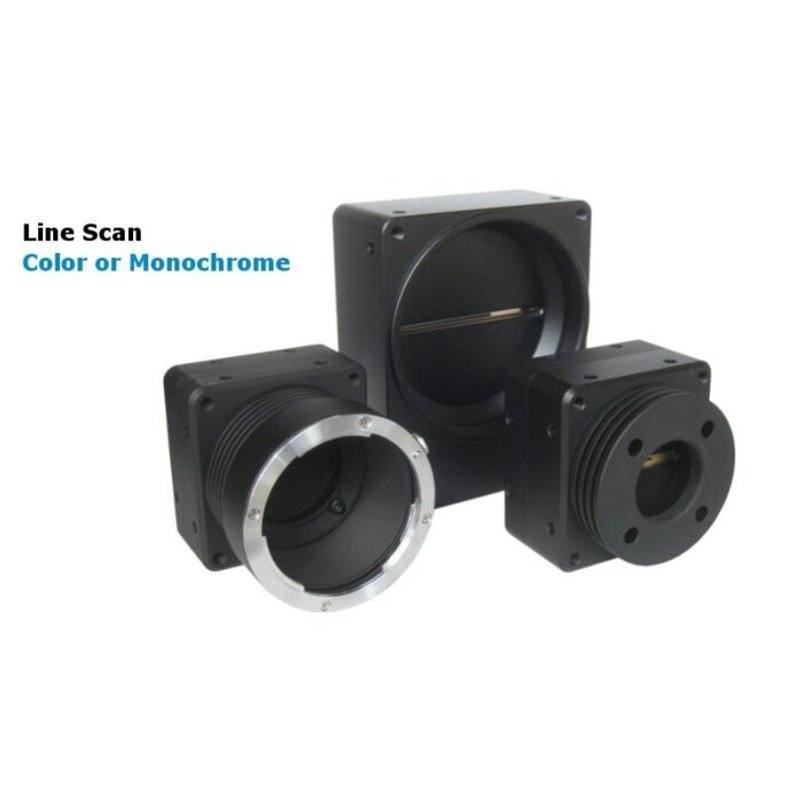
The Omron Sentech FS-B2KU7CL is a monochrome line scan camera built around a 2048-pixel line sensor with a 7 um pixel pitch. Unlike an area-scan sensor that captures a full two-dimensional frame in one exposure, a line scan camera acquires a single row of pixels at a time and builds a complete image as the object (or the camera) moves past the field of view. This makes it well suited to continuous-motion processes such as web, sheet, or roll-to-roll inspection, where the image is assembled line by line in perfect registration with the moving material. The monochrome sensor captures luminance directly without a colour filter array, so all of the available pixels contribute to the image, which generally yields better light sensitivity and finer effective spatial detail than a comparable colour device for defect and contrast-based inspection.
Acquisition runs at up to an 80 kHz line rate, meaning the camera can capture tens of thousands of lines per second. At a given material speed, the line rate sets how finely the moving direction is sampled, so a high line rate allows either faster line speeds or denser sampling along the travel axis while preserving resolution. To exploit this throughput the camera uses a Camera Link interface, a deterministic, frame-grabber-based connection that provides high, low-latency, real-time bandwidth and stable triggering, which is the conventional choice for sustained high-rate line scan data. Operation follows the GenICam standard, giving a vendor-neutral programming model for configuring features and integrating with compliant machine-vision software and frame grabbers.
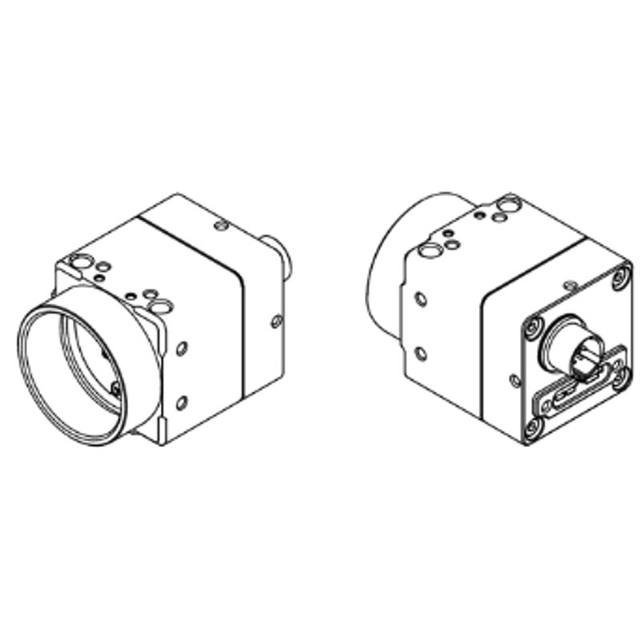
The camera offers an F-mount for lens attachment and runs from an external power supply rather than drawing power over the data interface. The F-mount provides the larger image circle and back focal distance typically needed to cover wide line sensors and longer working distances, and the external supply keeps the imaging electronics powered independently of the acquisition link. Together these characteristics position the FS-B2KU7CL as a building block for line-rate inspection systems where consistent, synchronised line capture across a moving product is the primary requirement.
Best for
Continuous surface inspection of moving web or sheet materials such as film, paper, foil, textiles, and coated substrates
Roll-to-roll and conveyor-based defect detection where the product moves past a fixed camera at constant speed
Line scan vision tasks requiring high line rates synchronised to an encoder for distortion-free imaging
Monochrome contrast and defect inspection where colour information is not required and maximum light efficiency is preferred
Inspection of long or continuous parts (extrusions, profiles, rails) that cannot be captured in a single area-scan frame
Selection notes
Line scan systems are encoder-driven: feed a motion encoder signal to trigger line acquisition so the image stays geometrically correct regardless of speed variation. The Camera Link interface supports the deterministic triggering needed for this, but requires a compatible frame grabber and the appropriate Camera Link cabling, which has limited reach compared with packet-based interfaces and may need repeaters or careful cable selection over longer runs.
Choose a lens that covers the sensor's image circle on the F-mount and resolves detail down to the 7 um pixel pitch; verify the lens MTF and image-circle coverage at your chosen working distance and magnification before committing to optics.
Lighting is critical at high line rates because each line is exposed only briefly. Plan for intense, uniform line illumination (for example, high-output line lights) aligned precisely with the sensor's line of view to maintain signal at 80 kHz and to avoid streaking or uneven response across the line.
Provide a stable external power supply sized for the camera; because power is not delivered over the data link, account for separate power routing and connector management in the cabinet and at the camera.
If your application needs colour discrimination, a single full-frame snapshot of a static scene, or a cable-powered single-connector interface, a monochrome line scan camera over Camera Link with external power may not be the right fit; consider an area-scan or colour model instead.
Specifications: General
Camera type
Line scan
Specifications: Sensor
Horizontal resolution
2k (2048 px)
Mono / color
Monochrome
Sensor manufacturer
ams (CMOSIS)
Sensor model
AWAIBA DR-2K-7
Pixel size
7 µm
Specifications: Performance
Line rate
80 kHz
Specifications: Interface
Interface
Camera Link
Protocols
GenICam
Specifications: Optics
Mount
F-mount
Specifications: Electrical
Power
External supply
This product groups every purchasable order code that shares the same sensing method, range and output. Cable length, connector type and operation mode (Light-ON/Dark-ON, NO/NC) vary by order code below.
Family variants with highlighted differences
Model
Mono / color
Interface
Availability
2k (2048 px) Monochrome Camera Link Base
Monochrome
Camera Link
On request
Applications this camera is commonly selected for. Open one to see the full recommended hardware and approach.
These steps take an Omron Sentech (STC) camera from the box to a stable first image and on to your own application. They apply across the GigE Vision, USB3 Vision and CoaXPress STC families; the interface only changes how you cable and power the camera.
Download and install the Sentech SDK on the host PC. The package provides StViewer, the viewing and configuration software you use to bring the camera up, and StApi, the programming SDK you integrate later. Because the cameras are GenICam/GenTL-compliant, StApi also registers a GenTL producer, so any GenICam-compliant third-party vision software can discover and drive the camera as an alternative front end.
2. Cable, power and connect the camera
Connect according to the interface. GigE Vision: link to a Gigabit NIC (use PoE or the separate power input) and put the camera and host on the same subnet; for USB3 Vision use a USB 3.x port and a certified cable; for CoaXPress (STC) connect to a CoaXPress frame grabber, which also supplies Power-over-Coax. Then open StViewer and let it enumerate the camera. If a GigE camera does not appear, check the IP configuration and firewall, and on USB3 confirm the host bandwidth and driver.
3. Configure exposure, gain and white balance
Open the device in StViewer and start a live stream. Set exposure and gain for a well-exposed, low-noise image: raise exposure first and only add gain when more light or a faster shutter is not an option, keeping exposure short enough to freeze motion on global-shutter models. On colour cameras, run white balance under your actual production lighting. Adjust the lens aperture and focus on a representative target before tuning anything else.
4. Set the trigger and grab a first image
Start in free-run (continuous) acquisition to confirm a clean, stable image. For inline inspection switch to hardware or software triggering: select the trigger source, set the active edge and any delay, and wire the strobe or illumination to the camera's I/O so lighting fires with each exposure. Acquire and save a frame in StViewer; this saved image is your reference for the SDK stage and for downstream inspection.
5. Move to the StApi SDK (or any GenICam software)
Once the image is stable, reproduce the same settings in code. Use StApi to open the device, apply the GenICam features you validated in StViewer (exposure, gain, trigger, pixel format) and grab frames into your application via the bundled C++, C, C#/.NET or Python interfaces; the included samples are the fastest starting point. Prefer a different stack? The same GenICam/GenTL camera works with third-party vision libraries. With a reliable feed, you can route it into a deep-learning inspection such as Rosepetal for AI-based defect detection.
Frequently asked questions
It is a line scan camera. It captures one 2048-pixel line at a time and builds a full image as the inspected material moves past the sensor, which is ideal for continuous web and surface inspection rather than imaging static scenes in a single frame.
The camera uses a Camera Link interface. This is a frame-grabber-based connection, so you will need a compatible Camera Link frame grabber and Camera Link cabling. It provides high, deterministic, low-latency bandwidth suited to sustained high line rates and precise triggering.
It is a monochrome camera. It captures luminance without a colour filter array, which typically improves light efficiency and effective spatial detail for defect and contrast inspection. If you need colour discrimination, choose a colour model.
It supports a line rate of up to 80 kHz. To keep images geometrically correct, synchronise line acquisition to the material's motion using an encoder so the sampling along the travel direction matches the actual product speed.
It is powered from an external supply rather than over the data interface, so plan separate power routing. It uses an F-mount, which offers the image circle and back focal distance commonly needed to cover line sensors and support a range of working distances.