
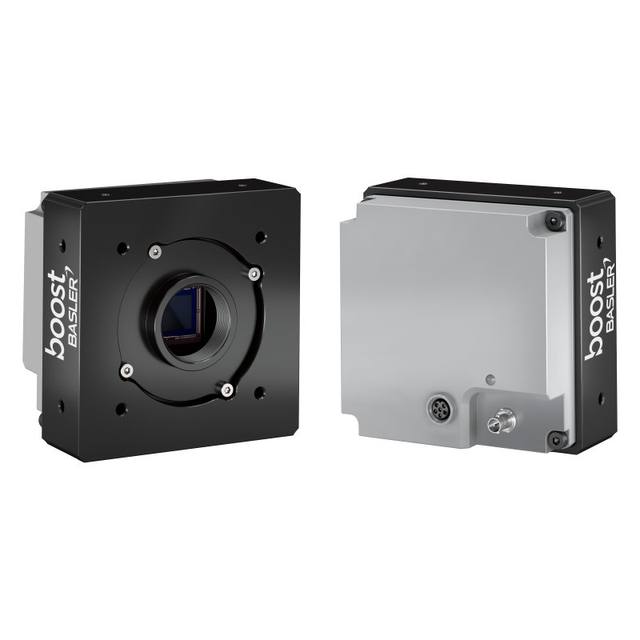
12 MP monochrome CXP-12 (CoaXPress 2.0) area scan camera with Sony IMX253 global shutter sensor delivering up to 69 fps.
- Rosepetal compatible
- Recommended by AIS Vision
On request
Cameras of 20-25 MP and above, CXP/10GigE and large format for electronics, semiconductors, display and metrology.
Related searches: 20MP 25MP 50MP camera, high resolution machine vision
High-resolution cameras exist to resolve detail that ordinary sensors cannot: a few-micron defect on a wafer, a sub-pixel edge on a precision part, a hairline crack on a display panel, or a wide field of view that still has to be read at fine pitch. Once you pass roughly 20-25 MP and into large-format sensors, the camera stops being the hard part of the system. The optics, the bandwidth, the lighting uniformity and the processing budget become the constraints that decide whether all those pixels are actually usable.
This guide is about getting value from the pixels you pay for. It covers the optics challenge that defeats most high-resolution builds, how to size the interface so the data actually moves, why illumination uniformity matters more at large format, and the recurring decision between one big sensor and several smaller ones. The aim is a specification where every megapixel reaches your inspection software as real, in-focus, evenly-lit information.
316 results
12 MP monochrome CXP-12 (CoaXPress 2.0) area scan camera with Sony IMX253 global shutter sensor delivering up to 69 fps.
The Basler boA4500-45cc CoaXPress camera with the onsemi XGS 20000 CMOS sensor delivers 45 frames per second at 20 MP resolution.
The Basler boost boA4500-45cm is a 20 MP monochrome CoaXPress CXP-12 area scan camera built on an onsemi XGS 20000 global shutter CMOS sensor delivering up to 46 fps.
A 20 MP color CoaXPress 2.0 (2x CXP-12) area-scan camera built on the Sony IMX531 global-shutter CMOS sensor, delivering up to ~100 fps at full resolution.
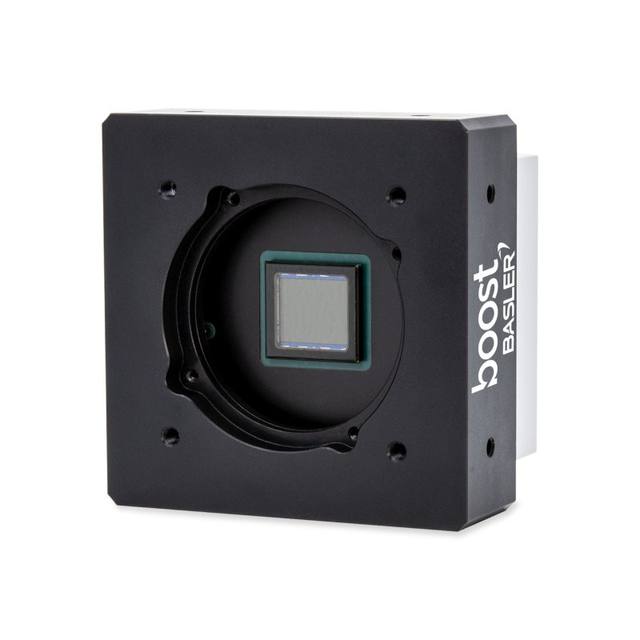
A 20 MP monochrome CoaXPress (CXP-12) area scan camera from the Basler boost series, built on the Sony IMX531 global-shutter CMOS sensor and running at up to 100 fps.
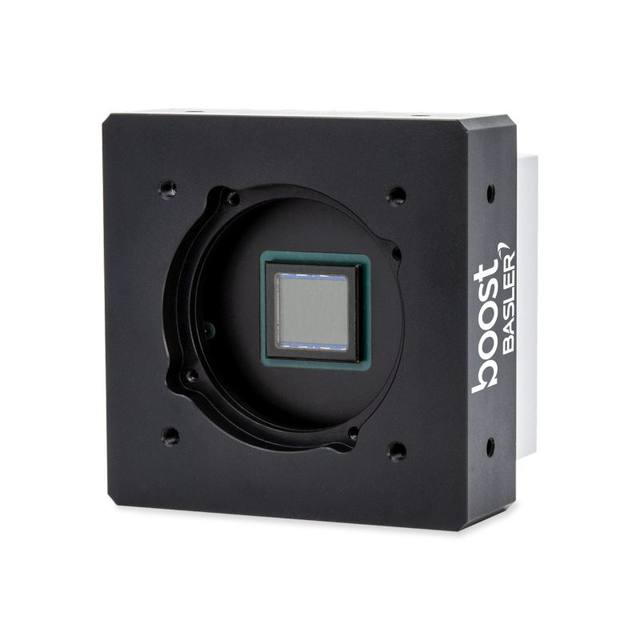
The Basler CoaXPress 2.0 boA5320-150cc camera with the Sony IMX532 CMOS sensor delivers 150 frames per second with a 16 MP resolution.
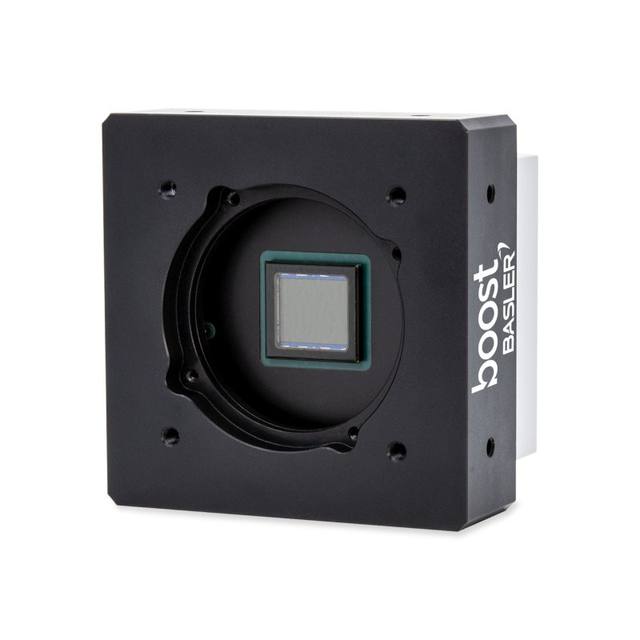
A 16.1 MP monochrome CoaXPress CXP-12 area scan camera from the Basler boost series, featuring a Sony IMX532 global shutter sensor at up to 150 fps.
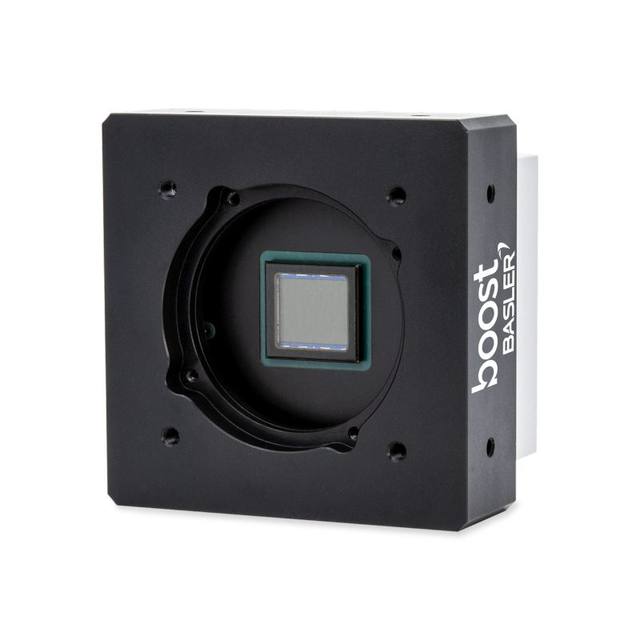
The Basler CoaXPress 2.0 boA5328-100cc camera with the Sony IMX530 CMOS sensor delivers 100 frames per second with a 24,5 MP resolution..
The Basler CoaXPress 2.0 boA5328-100cm camera with the Sony IMX530 CMOS sensor delivers 100 frames per second with a 24,5 MP resolution..
A 32.4 MP color CoaXPress (CXP-12) area scan camera from the Basler boost series, built on the onsemi XGS 32000 global shutter CMOS sensor and delivering up to 35 fps at full resolution.
32.4 MP monochrome CoaXPress CXP-12 area scan camera built on the onsemi XGS 32000 global-shutter CMOS sensor, delivering 35 fps at full resolution.
The Basler boost boA8100-16cc is a 44.7 MP color area scan camera with a CoaXPress CXP-12 interface, delivering 19 fps at full 8192 x 5460 resolution using an onsemi XGS 45000 global shutter CMOS sensor.
45 MP monochrome CXP-12 area scan camera with onsemi XGS 45000 global shutter sensor delivering 19 fps at 8192 × 5460 resolution via CoaXPress 2.0.
CoaXPress CXP-12 high-resolution area scan camera with a 65 MP Gpixel GMAX3265 global shutter CMOS sensor delivering 70 fps in color.

The Basler MED ace 20.0 MP 17 color USB 3.0 camera with the Sony IMX183 CMOS sensor delivers 17 frames per second at 20.0 MP resolution.
The Basler MED ace 20.0 MP 17 mono USB 3.0 camera with the Sony IMX183 CMOS sensor delivers 17 frames per second at 20.0 MP resolution.
5 MP (2448×2048) monochrome GigE area-scan camera with global shutter CMOS, C-mount, and Power over Ethernet, designed for high-resolution industrial machine vision in the MX-E Series ecosystem.
5 MP (2448×2048) GigE monochrome area-scan camera with 2/3" global-shutter CMOS sensor, 20 FPS, C-mount, and Power-over-Ethernet support.
5 MP GigE color area-scan camera with 2448x2048 resolution, 2/3" global-shutter CMOS sensor, 20 FPS, and Power over Ethernet support.
5 MP GigE color area-scan camera with 2448×2048 resolution, global shutter 2/3" CMOS sensor, 20 FPS, C-mount, and PoE support for industrial machine vision.
GigE Vision area-scan industrial camera with a 4.2 MP (2048x2048) 1" monochrome global-shutter CMOS sensor running at 25 FPS.
5MP (2592x1944) GigE area-scan camera with 1/2.5" CMOS rolling shutter sensor, 14 FPS, C-mount, and Power over Ethernet, designed for compact machine vision integration.
5 MP GigE area-scan camera with 2592×1944 resolution, 1/2.5" rolling-shutter CMOS sensor, 2.2 µm pixels, and C-mount, delivering 14 fps in grayscale.
The CAM-M197C-GE is a 5MP GigE color area scan camera with a 2592x1944 progressive scan CMOS rolling shutter sensor, delivering 14 fps over Power over Ethernet in a compact 42x29x29mm industrial housing.
The case for a high-resolution camera is built from two numbers: the field of view you must cover and the smallest feature you must reliably resolve. Divide one by the other, allow roughly three to five pixels across that smallest feature, and you have a target pixel count per axis. When that target lands beyond what a standard 5-12 MP sensor can deliver, you are genuinely in high-resolution territory. Typical drivers are large parts inspected whole at fine detail (electronics assemblies, full PCBs, display panels), metrology where sub-pixel edge fitting demands dense sampling, and semiconductor or wafer work where the feature size is simply tiny.
Before committing, test the cheaper alternatives honestly. If the part can be split into zones inspected in sequence on a stage, a smaller sensor with multiple acquisitions may cost far less in optics and processing. If the object moves continuously and is long or cylindrical, a line-scan camera often delivers effective resolution that no area sensor can match across a web. A high-resolution area-scan camera is the right answer specifically when you need the whole field at once, frozen in a single exposure, at a detail level a smaller sensor cannot reach. Choosing it for any other reason usually means paying the high-resolution tax — in lenses, bandwidth and compute — without the benefit.
This is where high-resolution projects most often fail. A large sensor demands a lens that covers its full diagonal — its image circle — without darkening or softening at the corners. Many familiar C-mount lenses are specified for sensors up to around 1 inch; a 20-25 MP or larger sensor frequently needs a larger format and a correspondingly larger mount (F-mount, M42, M58 or similar) just to be covered at all. Mount a sensor whose diagonal exceeds the lens image circle and you get vignetting and a blurred, low-contrast border that no software can recover. Confirm image-circle coverage before anything else.
Coverage is necessary but not sufficient. A large sensor at high pixel count has very small pixels, often in the low single-digit micron range, and the lens has to resolve detail at that pitch — across the entire frame, corner to corner, at the working aperture you intend to use. This is an MTF (modulation transfer function) question, not a megapixel-rating question: the lens must deliver adequate contrast at the spatial frequency your pixel pitch implies (roughly line pairs per millimetre equal to 1000 / (2 x pixel pitch in microns)). A sensor that out-resolves its lens simply spreads each real detail over several pixels — you store more data but see no more. Diffraction sets a hard ceiling too: stopping a lens down to gain depth of field eventually blurs fine detail (the diffraction spot grows past the pixel), so high-resolution systems often run at moderate apertures and recover depth of field through fixturing instead.
For metrology, telecentric lenses remove the perspective error that makes a part appear to change size with distance, but large-format telecentric optics are bulky and expensive because the front element must be at least as large as the field of view. Plan optics and budget together: at this resolution the lens can cost as much as the camera, and a cheap lens on an excellent sensor is the single most common way to waste the investment.
A high pixel count multiplies the data rate fast. A single 25 MP frame is around 25 MB at 8-bit, doubling near 50 MB at the 10-12 bit depths metrology often needs, and at even modest frame rates the resulting stream overwhelms ordinary interfaces. This is why the category is built around CoaXPress and 10GigE rather than standard GigE or USB3. The interface choice is dictated by the product of resolution, frame rate and bit depth, and it should be sized comfortably above your peak rate — running a link near its ceiling is how high-resolution systems acquire intermittent dropped frames that are miserable to debug on a line.
CoaXPress (CXP-12, and multi-link configurations) delivers multiple gigabytes per second over coax and is the workhorse for the fastest, largest sensors, at the cost of a frame grabber in the host and the slot, cabling and cooling that implies. 10GigE (NBASE-T / 10GBASE-T) reaches similar usable throughput over standard Ethernet with longer cable runs and no grabber, trading some host-side complexity for simpler, more distributed cabling — attractive when the camera sits far from the PC or when several cameras feed one network. Both are well represented in the catalog across Basler, iRAYPLE and Omron/Sentech (STC); let the required bandwidth and cabling topology drive the choice rather than the badge. Whichever you pick, verify the host can actually sustain the rate: PCIe lane allocation, NIC capability, CPU and storage all have to keep up with the camera, or the bottleneck simply moves downstream.
Illumination problems that are invisible at low resolution become glaring across a large, finely-sampled field. A big sensor covers more physical area, so any falloff, hotspot or gradient in the lighting is spread across millions of pixels and shows up as a shading pattern that masks low-contrast defects and shifts measured edge positions. The larger the field of view, the harder it is to light it evenly, and the more the lens's own corner falloff (natural vignetting, which worsens with field angle) adds to the problem.
Treat uniformity as a first-class requirement, not an afterthought. Favour lighting geometries that flood the whole field evenly — large diffuse or dome sources, properly sized backlights for silhouette and dimensional work, sometimes tunnel or coaxial arrangements for flat specular parts — and size the illuminated area generously beyond the field of view so you are using the flat centre of the light, not its falling edge. Short exposures, which large high-resolution sensors often need to freeze motion or hit a cycle time, demand a lot of light, so plan for strong, stable, ideally strobed sources synchronised to the trigger. Where residual non-uniformity remains, flat-field (shading) correction calibrated against a uniform reference can normalise the response, but it is a correction layer on top of good optics and lighting, never a substitute for them.
When one sensor cannot cover the field at the detail you need, the real decision is between one larger sensor and several smaller ones tiled across the field. A single high-resolution camera keeps the system mechanically and softwarely simple — one acquisition, one image, one calibration — but pushes the difficulty into the optics (a lens that covers and resolves a large format) and into a heavy per-frame data and processing load. A multi-camera array uses cheaper, more available sensors and lenses and spreads the bandwidth across links, but adds the engineering of mounting and aligning several cameras, synchronising their triggers, and stitching or registering the images into a coherent result. For very wide fields, multiple cameras (or line scan) are often the only practical route; for a compact field that simply needs dense sampling, one large sensor is usually cleaner.
Whichever path you take, budget for what happens after acquisition, because it is routinely underestimated. Large images are expensive to move, store and process: every algorithm runs over far more pixels, so inspection cycle times, memory footprint and CPU or GPU load all scale with resolution. A 50 MP frame is not five times the work of a 10 MP frame in isolation — host transfer, decoding, and any deep-learning inference can scale faster than linearly depending on the pipeline. If a deep-learning stage such as Rosepetal sits downstream, factor the inference cost of full-resolution images explicitly; tiling, region-of-interest cropping or running detection at reduced scale and confirming at full scale are common tactics to keep cycle time in budget. The honest comparison is total cost of ownership — camera plus optics plus grabber or NIC plus the compute to process every frame in time — not the price of the camera alone.
How to size camera resolution from field of view and the smallest defect using the 3-5 px rule, plus why optics, lighting and bandwidth cap usable resolution.
When to choose monochrome vs color machine-vision cameras: Bayer light loss and effective resolution, color-dependent tasks, wavelength-specific lighting, NIR sensitivity and processing cost.
When 20+ MP cameras earn their place in inspection: sensor formats, the optics and MTF challenge, bandwidth and interfaces, lighting uniformity, and single high-res vs multi-camera.
We help you choose high-resolution cameras based on your application, FOV, working distance and environment.